


Copyright © 2026 Samshad Nc. All rights reserved.
Hi, I'm Samshad!
Robotics ResearcherEngineerDeveloper
Researcher with 8+ years of experience, currently at NUS Singapore, exploring how machines see and understand the world.
- Nice to meet you!
SAMSHAD NC
RESEARCHER | ENGINEER | EXPLORERCoderPlayerI'm Mohamed Samshad, a Robotics Researcher at the National University of Singapore (NUS). My research focuses on building better representations of environments and objects that help robots understand and reason about their surroundings, enabling better task planning and execution.
My work spans Visual SLAM, 3D Scene Understanding, and Vision-Language Models, focusing on semantic and spatial representations that help robots reason about their environment.
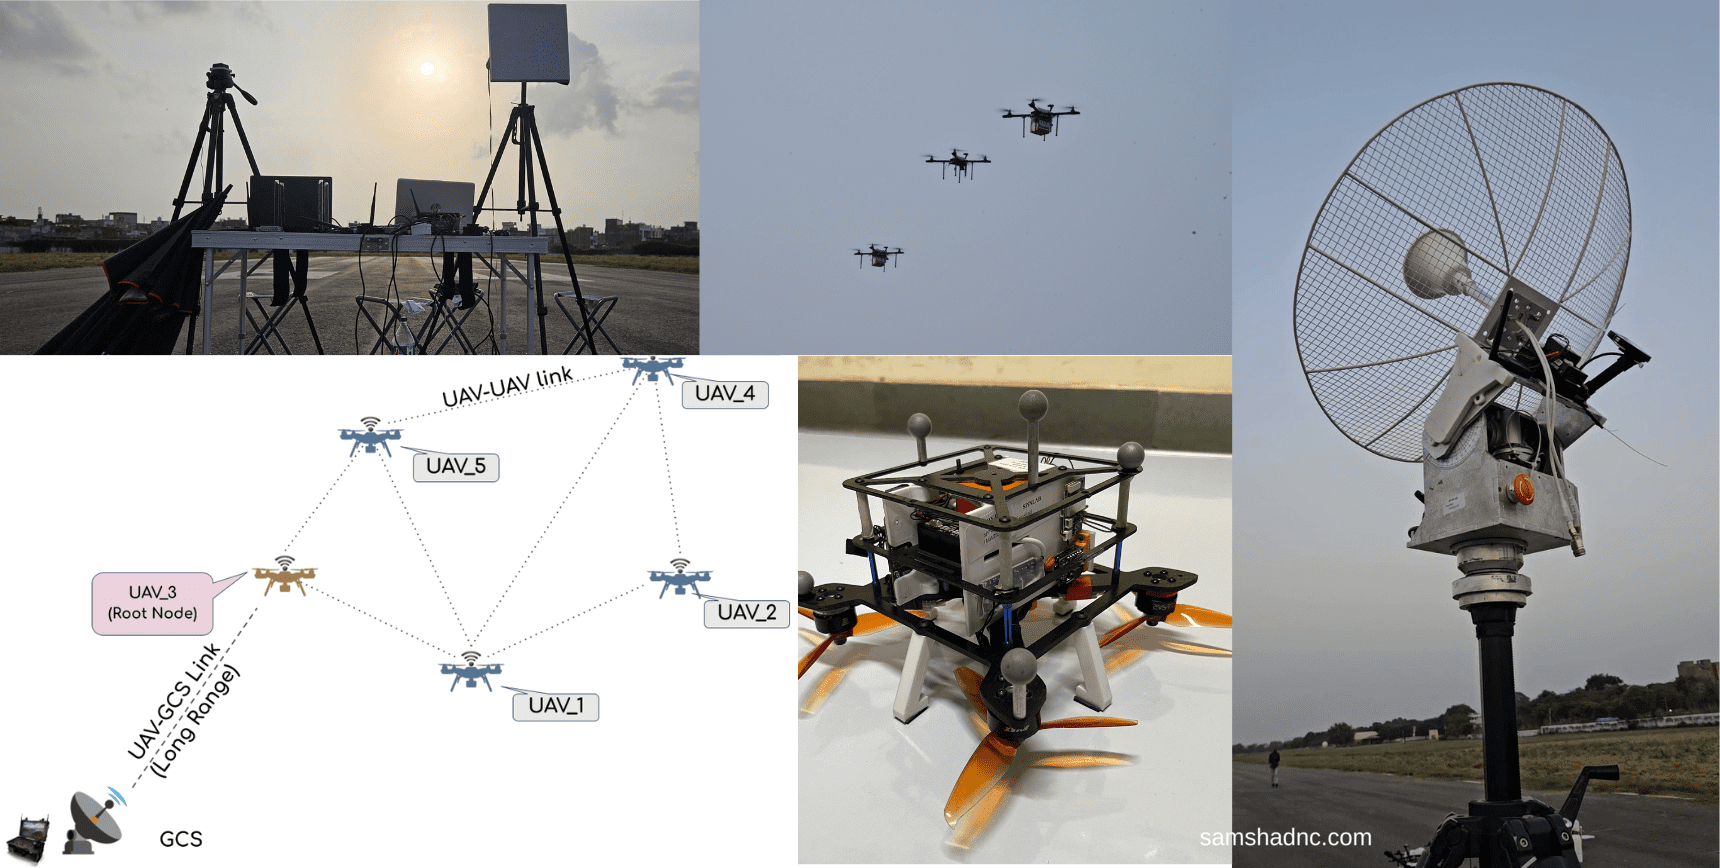
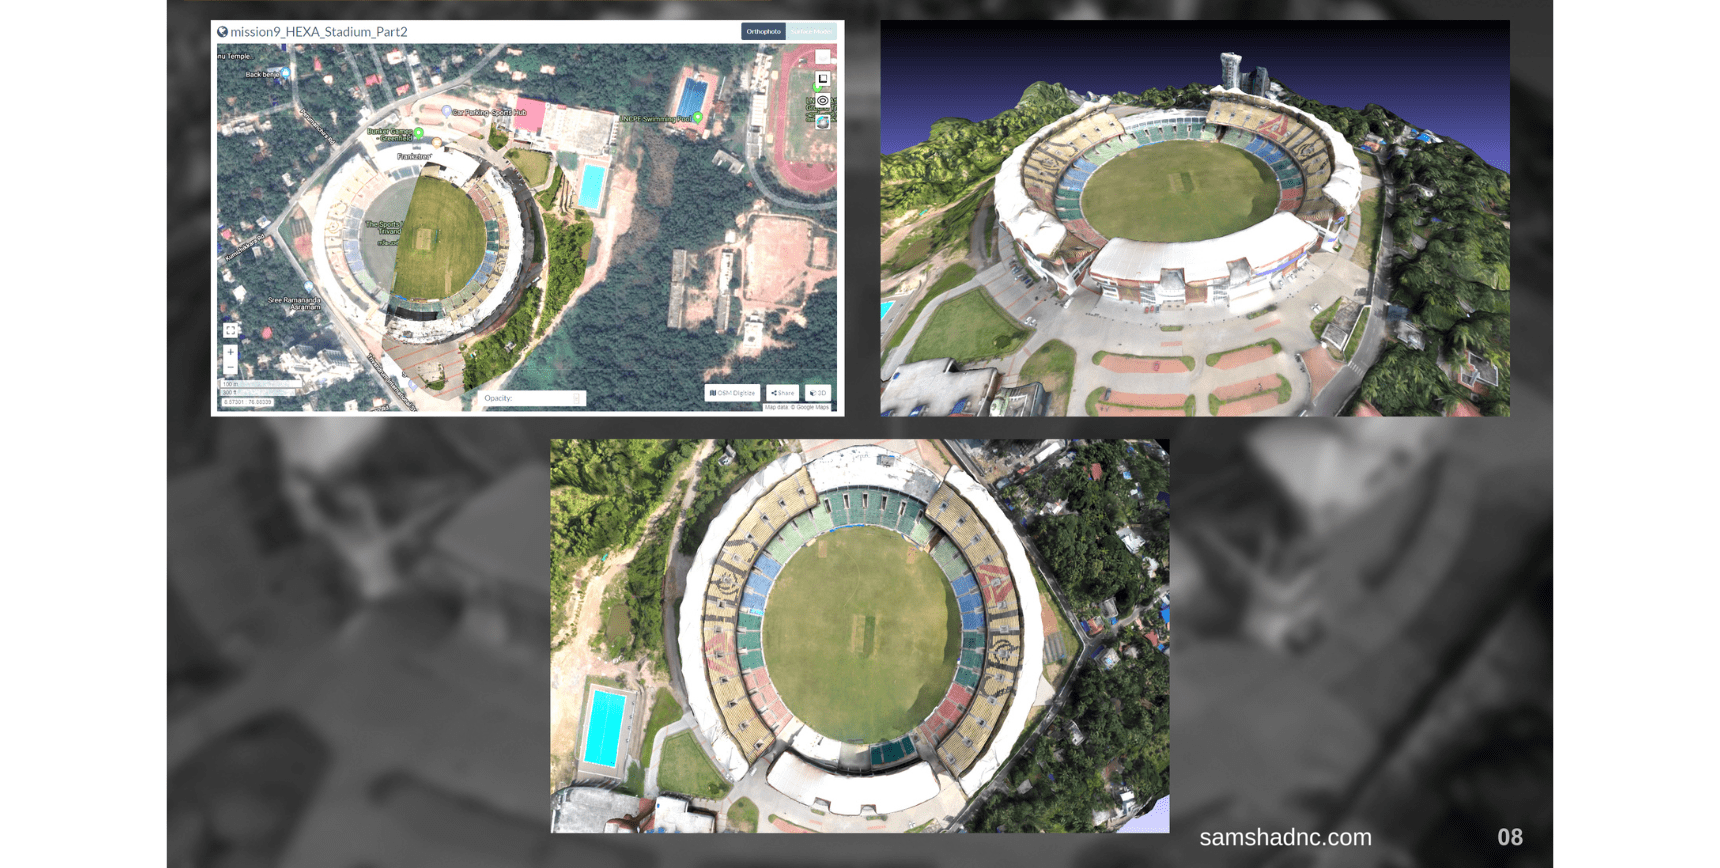
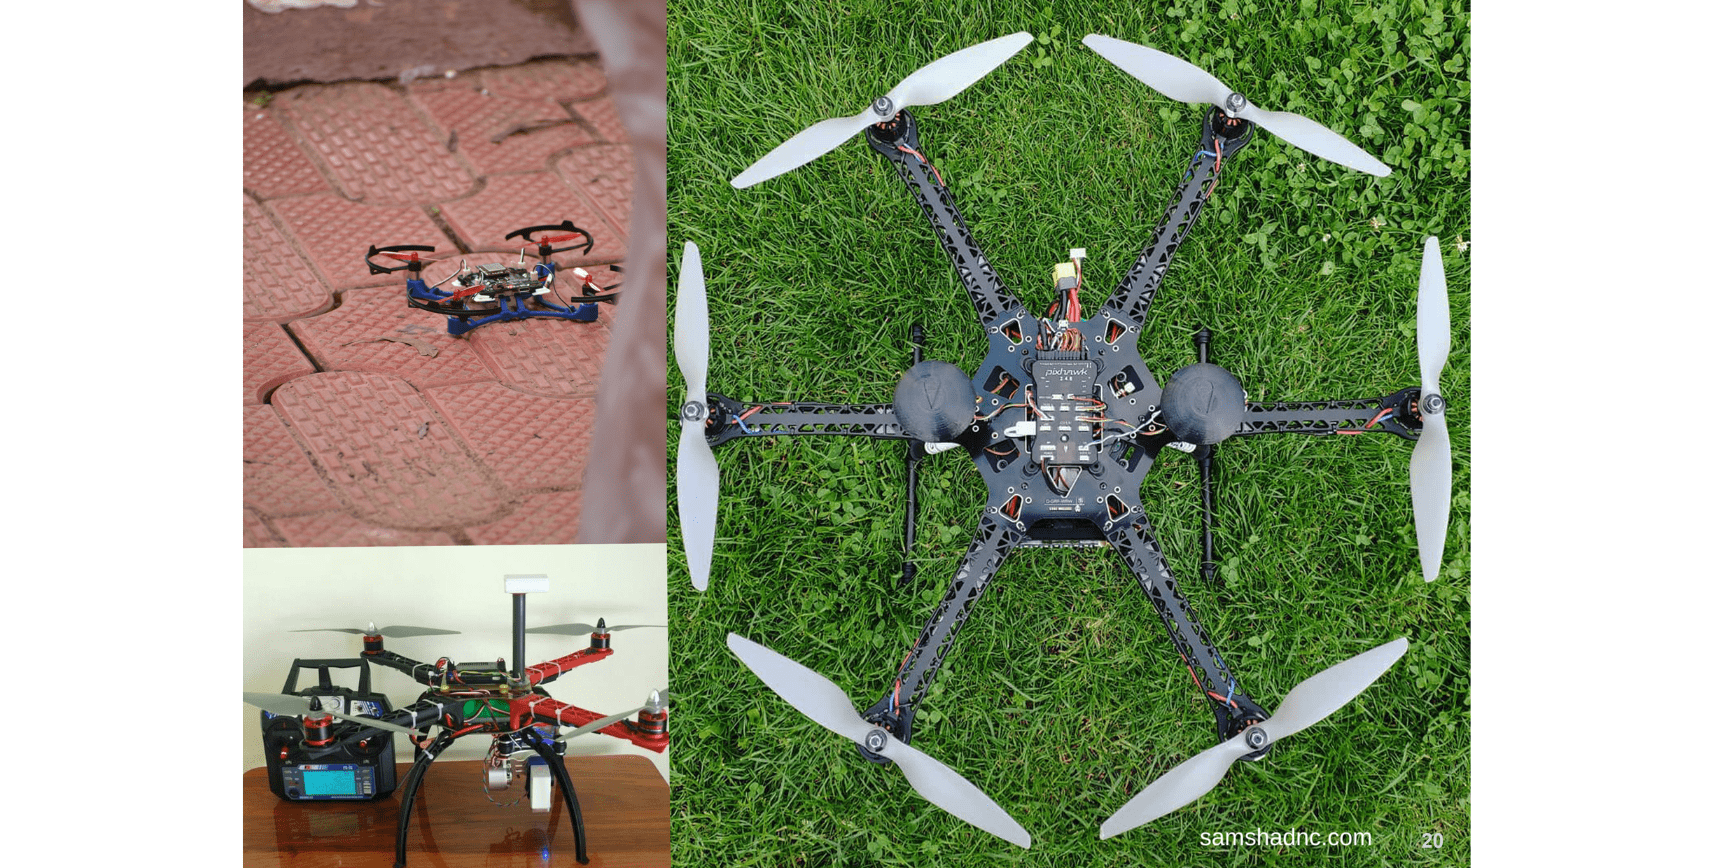
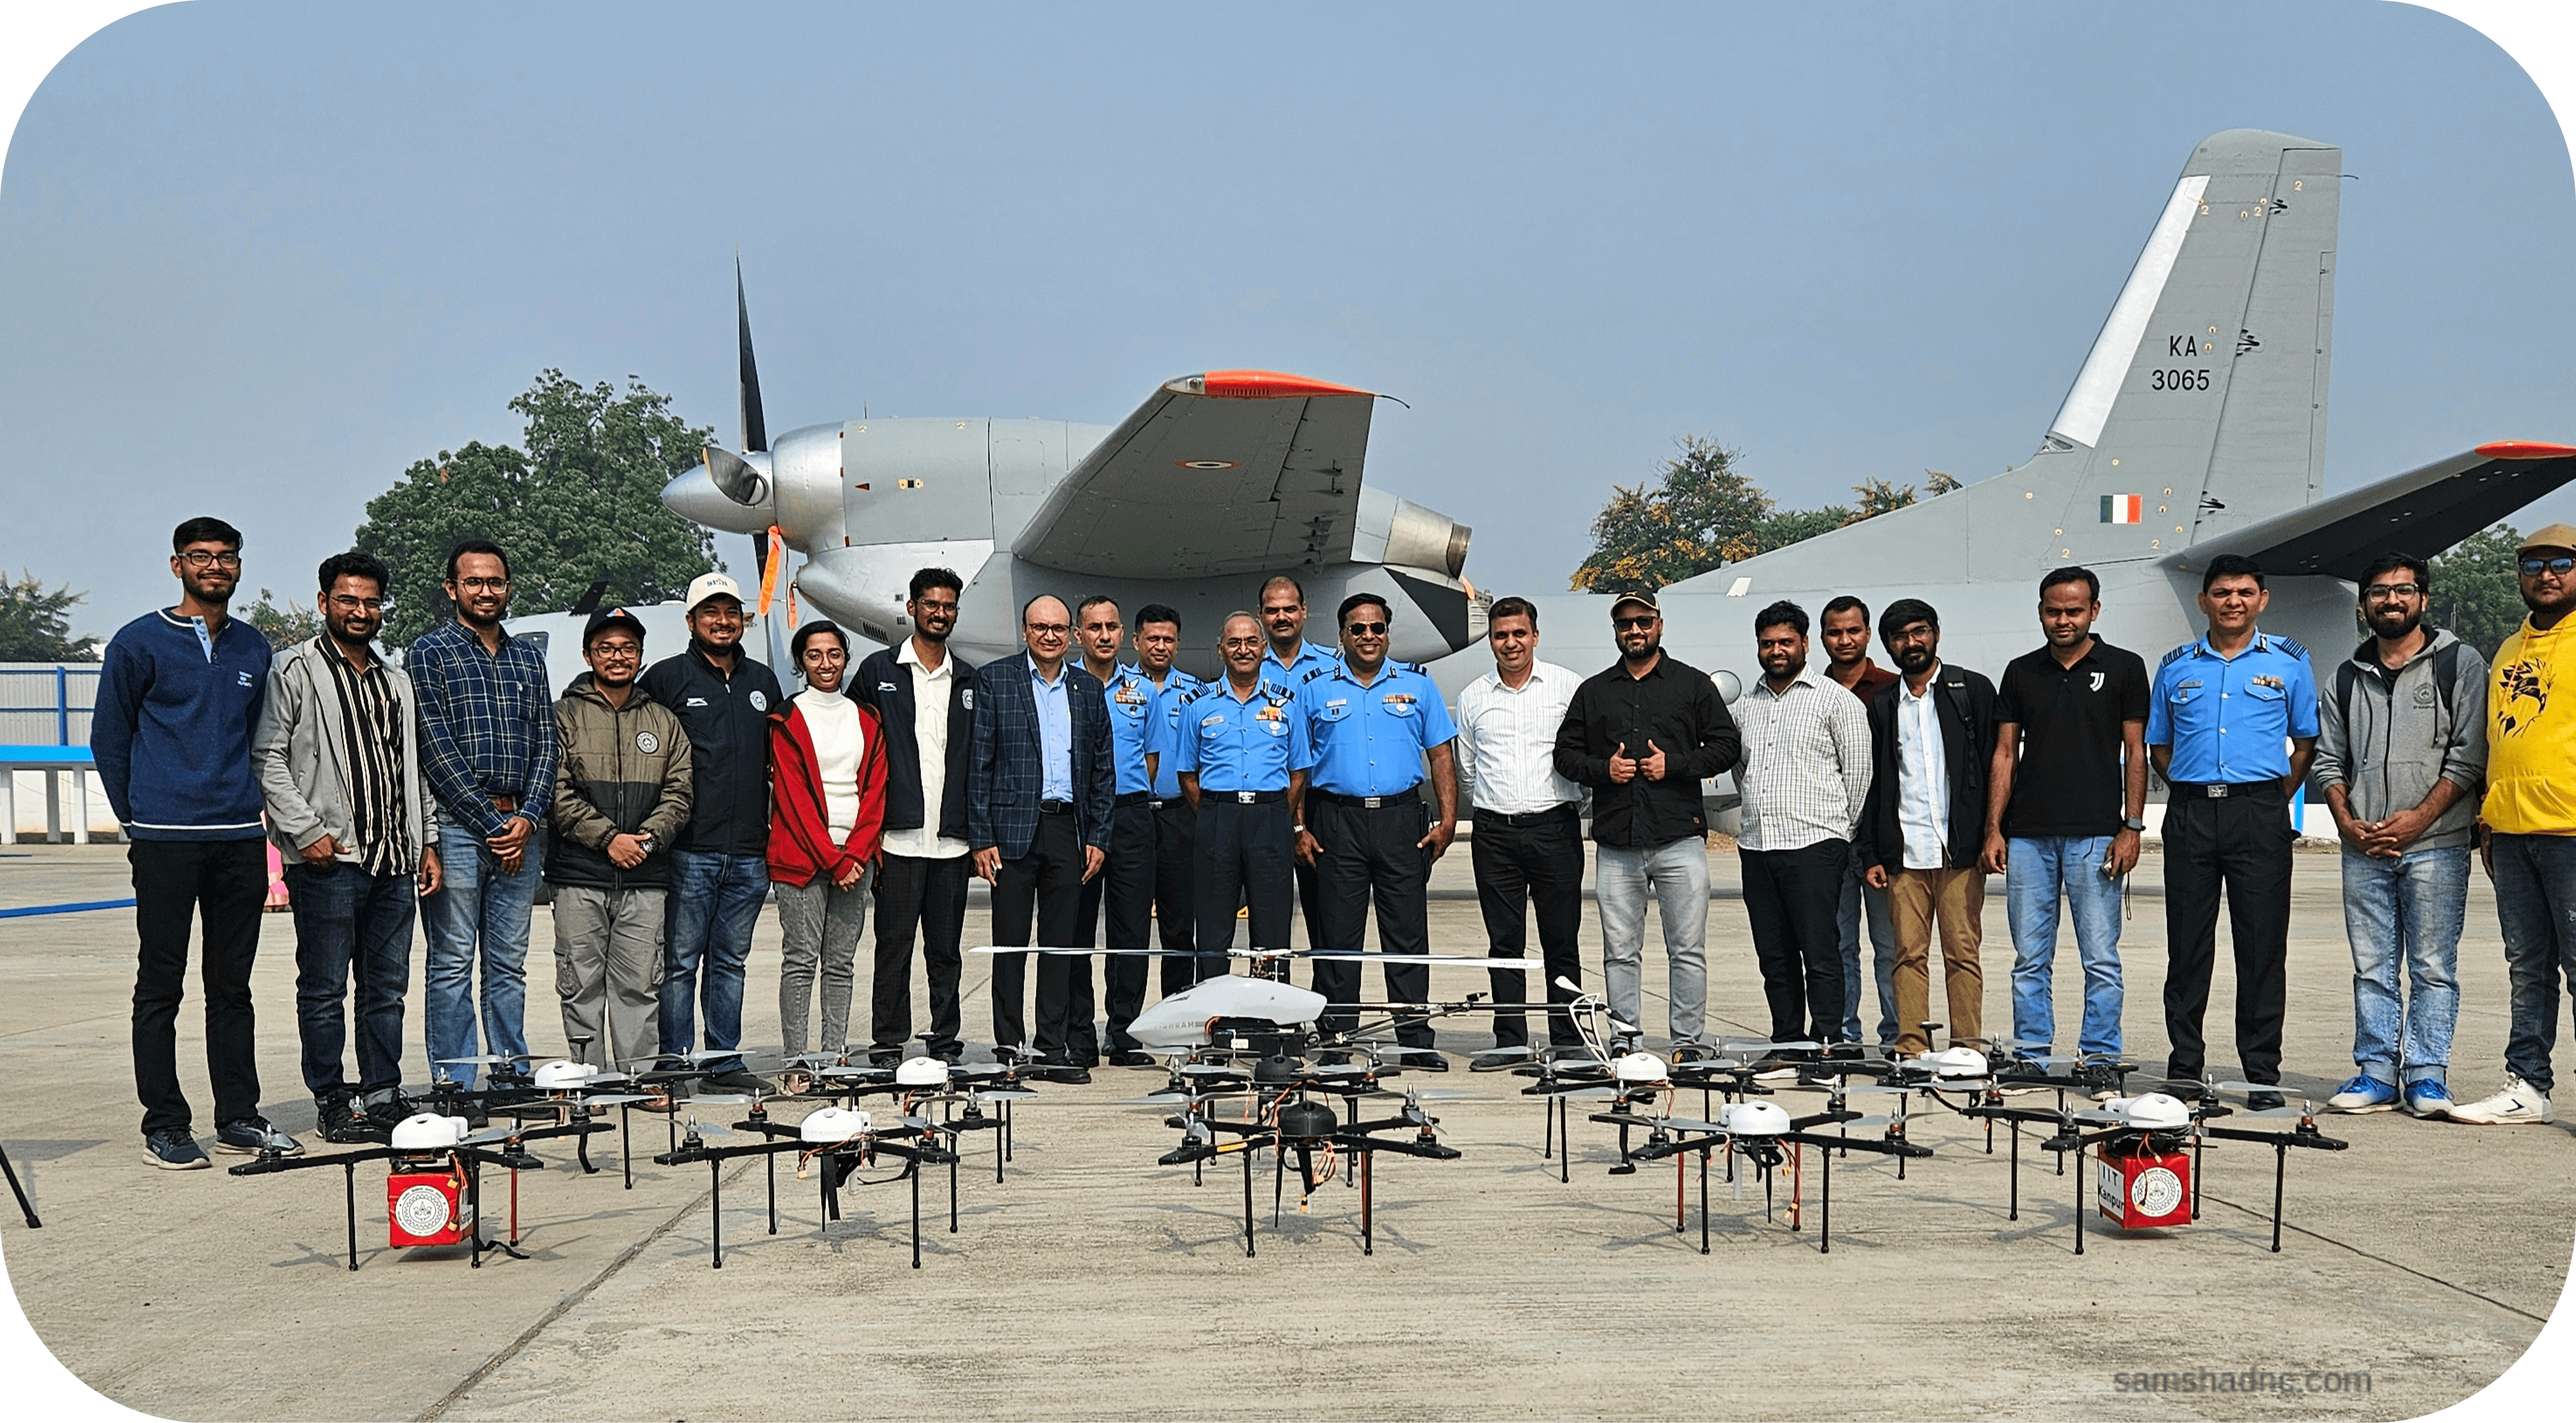
With 8+ years of experience in robotics, I began with UAV development and open-source drone projects before leading the Multi-UAV Research Group at IIT Kanpur, where I worked on multi-robot coordination, autonomous systems, and system optimization.
I hold a B.Tech. in Electronics and Communication Engineering from the University of Kerala and an MS by Research in Electrical Engineering from IIT Kanpur, where I also trained and mentored industry professionals and research students in robotics and autonomous systems.
Recent Activities


My Professional Journey



Publications
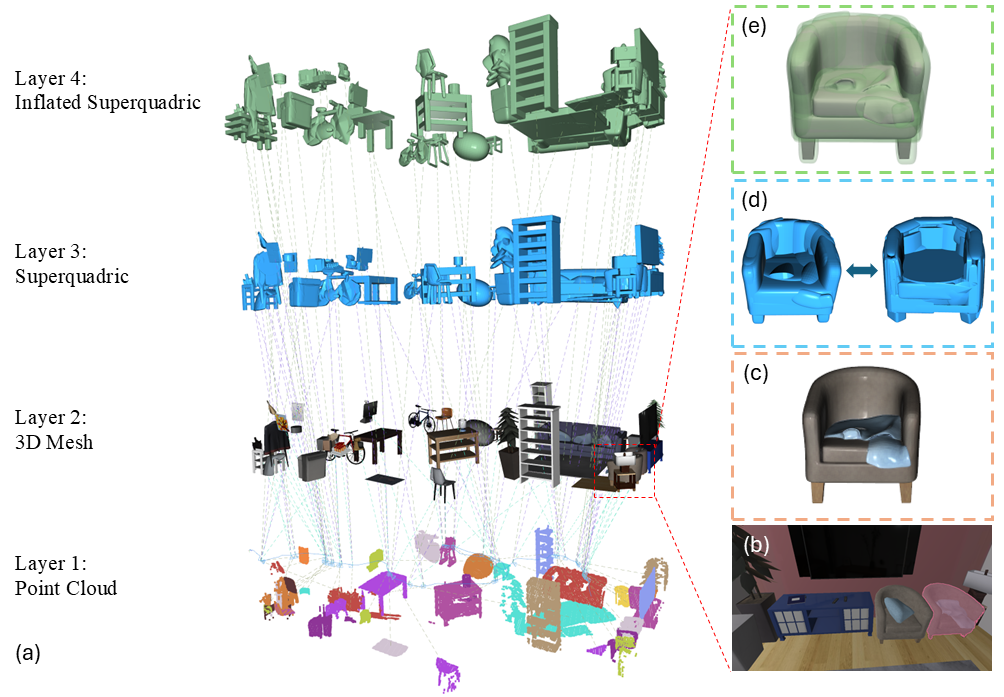
- C Zhang, W Su, M Samshad, GS Chirikjian and R Talak, "Hierarchical Object Representation for Spatial Robot Perception: Points, Meshes, and Superquadrics," International Symposium of Robotics Research (ISRR), 2026 (Accepted).
- R Harisankar, M Samshad, SS Muni and A Kaushik, "Hyperchaotic Trajectory Planning for Quadrotor Surveillance of Infrastructure with Integrated Collision Avoidance," International Journal of Bifurcation and Chaos, 36(14), 2630031, 2026.
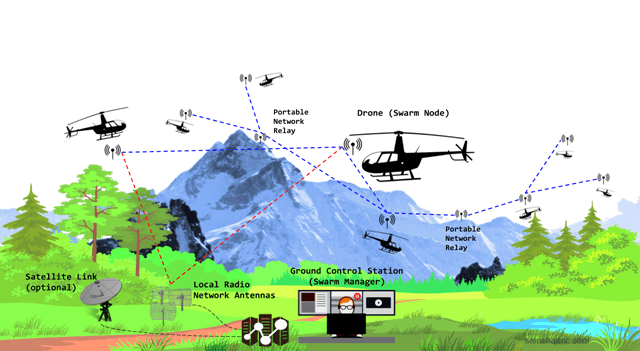
- S K Roy, M Samshad and K Rajawat, "UNet: A Generic and Reliable Multi-UAV Communication and Networking System Architecture for Heterogeneous Applications," IEEE Transactions on Network and Service Management, 2026.
- H Ravikumar, M Samshad, SS Muni and A Kaushik, "Novel 3D Chaotic Quadrotor Trajectories for Infrastructure Monitoring," Intelligent Service Robotics, 19(2), 26, 2026.
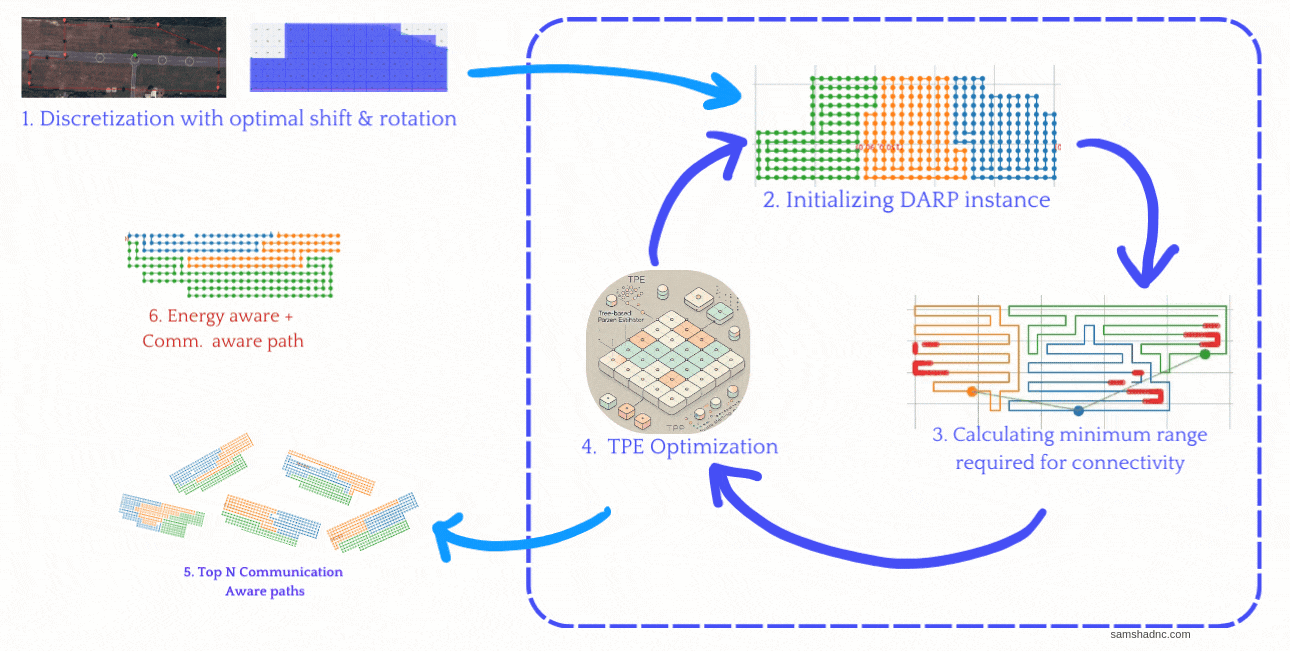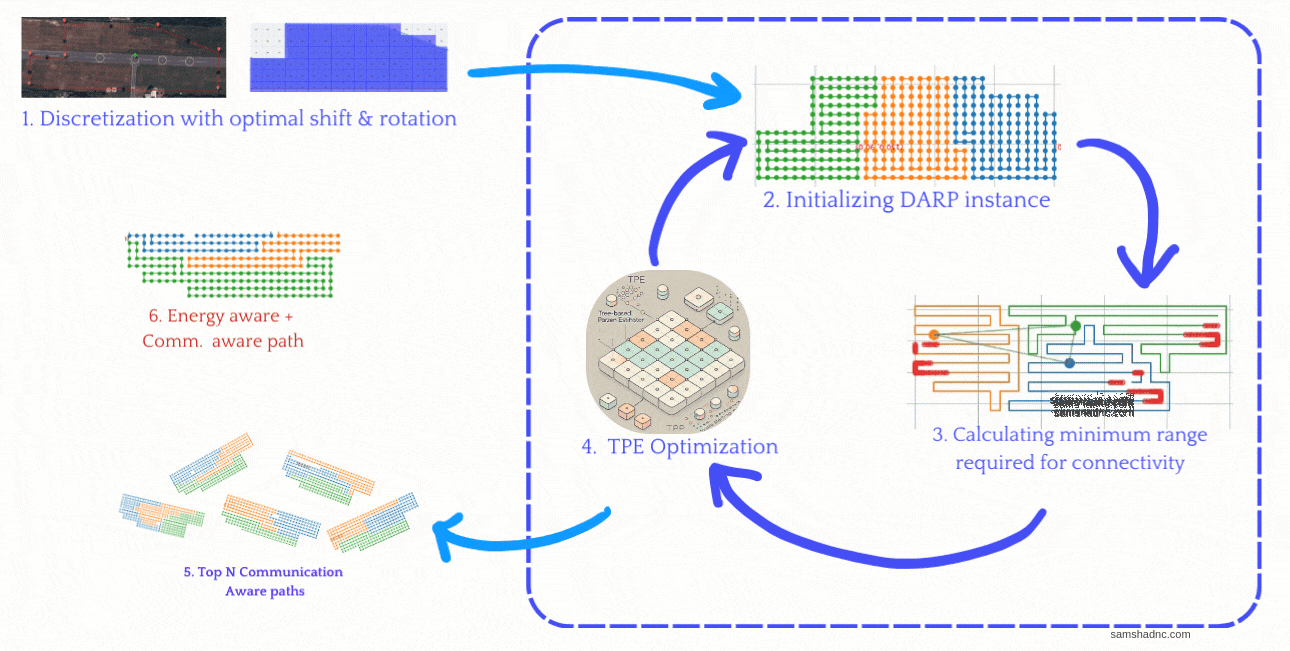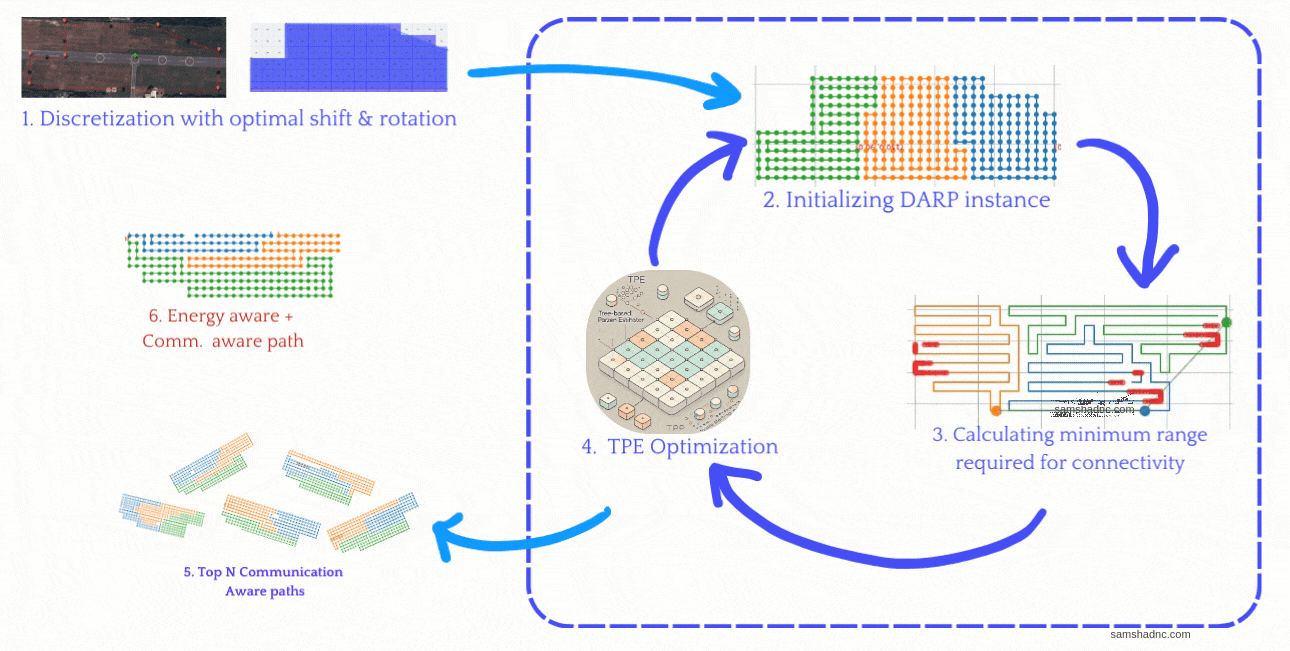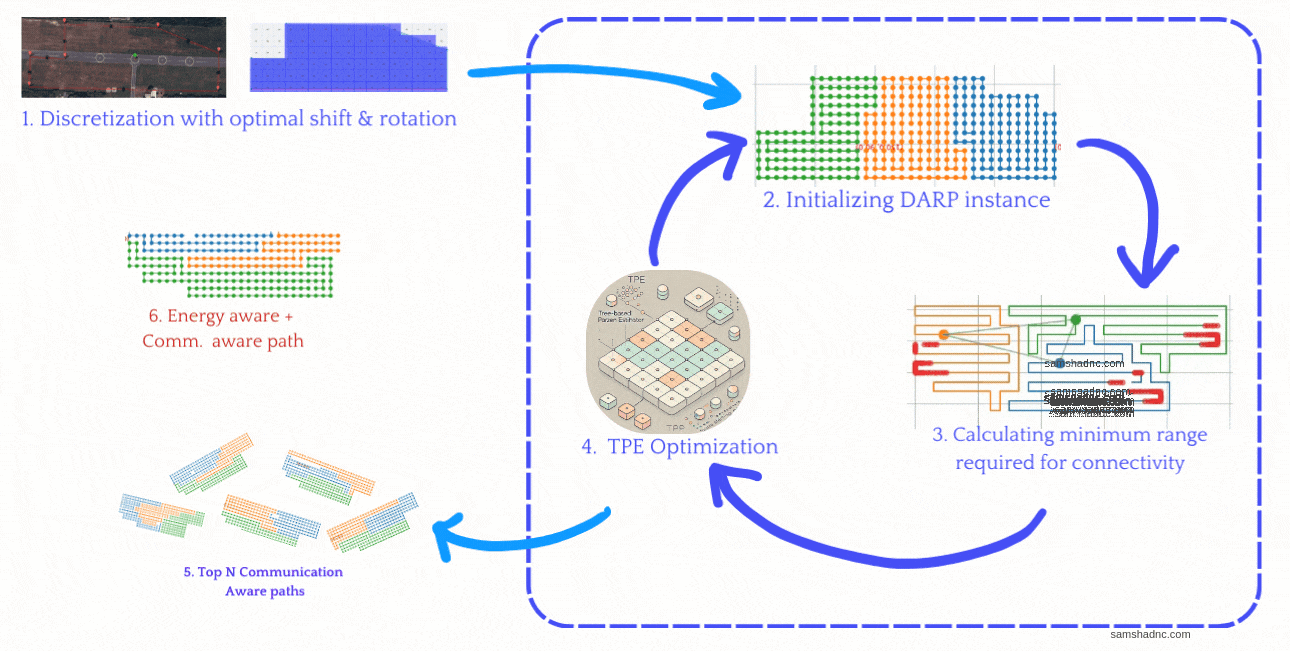
- M Samshad and K Rajawat, "Communication and Energy-Aware Multi-UAV Coverage Path Planning for Networked Operations," IEEE Robotics and Automation Letters, 2024 (Under Review).
- M Samshad, PP Pradhan, Ketan Rajawat and Mangal Kothari, "CNet: A Reliable Compact Multi-UAV Communication Architecture for Low Bandwidth Connectivity," The American Institute of Aeronautics and Astronautics(AIAA SciTech Forum), 2025.
- M Samshad and K Rajawat, "SkyNet: The Framework of Decentralized Multi-UAV Operations," Engineers Conclave, Inter IIT Conference, IIT Madras, December 2023.
- M. S. Sruthi, M. J. Poovathingal, V. N. Nandana, S. Lakshmi, M Samshad and V. S. Sudeesh, "YOLOv5 based Open-Source UAV for Human Detection during Search And Rescue (SAR)," 2021 International Conference on Advances in Computing and Communications (ICACC), Kochi, Kakkanad, India, 2021, pp. 1-6.
- M, Anand & A, Asok & Francis, Athul & Mohan, Karthika & R, Midhun & M Samshad, "Short Range Telemetry Communication for Autonomous Drone Navigation." IEEE-RAICS International Conference on Recent Advances in Intelligent Computational Systems (IEEE RAICS 2020), IEEE Kerala Section.
- Karthik J, Amalu S Panicker, Adarsh Sudarsanan, Sachu Pradeep, M Samshad, Arun C, Praveen Raj, "Air Pollution Detection Using UAV." International Journal of Innovative Research in Technology (IJIRT), Volume 8 Issue 1, June 2021.

Blog & Notes
Technical write-ups and project notes on UAV development, ROS, embedded systems, and open-source robotics tools.
Get in touch
Feel free to reach out for research collaborations or project discussions.
